PicterGro is an automated robot to serve the Earth and the enviroment!
This was designed for a robot design challenge hosted by PTC Waterloo in the Robotics Rebooted event.
This design took appoximately 10 hours to complete on Fusion 360, and PicterGro won first prize for the challenge!

There are 3 main functions of PicterGro:
- Picking fruit / vegetables / plants
- Planting trees
- Watering plants / trees
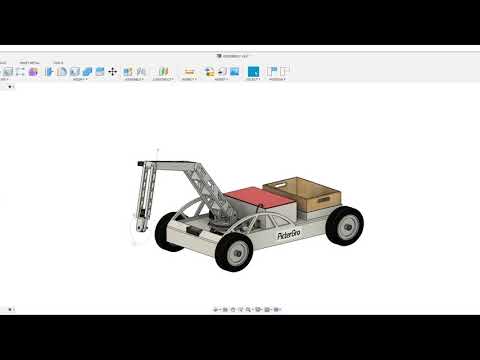
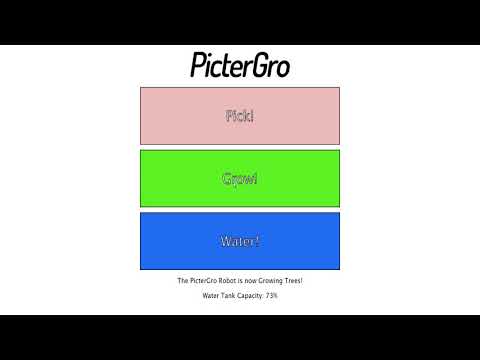
All of the functions are attached onto a huge robotic arm on a base made from sheet metal. A water tank and wooden basket is put behind the arm. The water tank supplies water to the sprinkler that is attached by the gripper, which is made possible by the water pump. The wooden basket is for the robot to put the vegetables or fruits, just like a farmer would collect apples in a basket. Also, the wooden basket can be used to put tree seedlings which the robot will pick it up and plant the tree. Everything is controlled on an online website, and everything is connected through the circuity and an Arduino. The robot is accompanied by two cameras; a primary camera embedded within the sheet metal base and a secondary camera that is above the gripper. Cameras will provide vision to the programs that use algorithms to identify obstacles, create pathaways, and to see where the gripper is going. Finally, the mechanisms are all powered by servo motors and a stepper motor.
Interested in learning more?
Check out my slideshow that I made to present PicterGro!
https://docs.google.com/presentation/d/1rZMRSgZxJUn-KpXbrpccTkQAfvvW1_FMM-mFlaCCQCU/edit?usp=sharing
[Click on Thumbnails for YouTube Demo Videos]